

How to Sensor with Devicetree (on Raspberry Pi)
Wednesday, 21st October, 2026 10min #raspberry_pi #hardware #linux #dlr
In the beginning there was the Arduino.
The way you read out a sensor on an Arduino is by using libraries:
You search for your sensor's Arduino library and use its API.
This library code runs as part of the application's code directly on bare-metal — without an operating system.
On desktop Linux, however, your code runs as a process and doesn't directly interact with the hardware.
Instead, the Linux kernel provides abstractions over the hardware; like a filesystem for storage or ALSA for audio.
Firstly, the motherboard's firmware (i.e., UEFI/BIOS) tells Linux what hardware is needed to boot.
Secondly, Linux automatically enumerates certain devices, e.g., those over USB or PCIe.
Therefore, the user and application developer don't need to worry about telling Linux what hardware there is.
But then there's embedded Linux:
We have a Raspberry Pi 5 Compute Module with
- a DS18B20 temperature sensor connected via One-Wire,
- an MCP3008 Analogue-to-Digital Converter (ADC) connected via
SPI0and chip-selectGPIO18and - an AISIH accelerometer connected via
SPI1and chip-selectGPIO16.
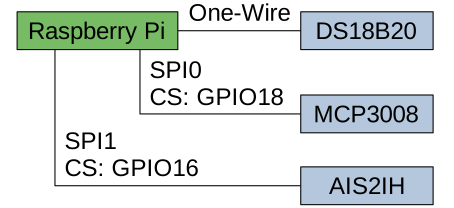
How do you configure these sensors? For one, the drivers need to know what SPI interface with what chip-select pin interfaces the hardware. There's no enumeration procedure that could do this, so how to do it? This article gives an introduction to Devicetree, the answer to the above questions.
Devicetree: How the Bootloader tells Linux What it Runs On
If your Linux uses Devicetree you can run dtc -I fs /sys/firmware/devicetree/base to print out the currently loaded device tree (on x86 this is quite rare but on ARM, like on a Raspberry Pi, Devicetree is quite ubiquitous).
Here is an example extract:
spi@50000 {
    pinctrl-names = "default";
    #address-cells = <0x01>;
    num-cs = <0x02>;
    pinctrl-0 = <0x2b 0x2c>;
    clock-names = "ssi_clk";
    interrupts = <0x13 0x04>;
    clocks = <0x02 0x0c>;
    #size-cells = <0x00>;
    dma-names = "tx", "rx";
    compatible = "snps,dw-apb-ssi";
    status = "okay";
    reg = <0xc0 0x40050000 0x00 0x130>;
    phandle = <0x6e>;
    dmas = <0x2a 0x0d 0x2a 0x0c>;
    cs-gpios = <0x2d 0x12 0x01>;

    adc@0 {
        vref-supply = <0xa1>;
        spi-max-frequency = <0xf4240>;
        compatible = "microchip,mcp3008";
        reg = <0x00>;
    };
};
In this example there are two nodes describing hardware: an spi@50000 node with a single child, an accelerometer@0 sensor.
Notice how the spi@50000 node specifies what chip-select pins are under this interface's control, only GPIO18.
This allows the child, accelerometer@0 to set the reg attribute to <0>, selecting the first and only chip-select pin.
If you had other or more chip-select pins, you would need to change the Devicetree accordingly.
Another important detail is the compatible attribute.
It's purpose is to let Linux choose what driver to load.
By specifying microchip,mcp3008 Linux will load the kernel respective module (unless the driver is already compiled into the kernel itself).
Therefore, the user doesn't need to worry about having the right kernel modules loaded; pretty neat, right?
Let's slowly get to how to adjust the Devicetree.
The extract above could be part of a Devicetree source (.dts) file.
We won't go into the details of the Devicetree specification and invite you to read the well-written specification, instead.
But as you might have guessed, dtc, the Devicetree Compiler, converts the loaded Devicetree from the virtual filesystem into the Devicetree source representation.
Besides the source and filesystem representation there also is the Devicetree blob representation(.dtb or .dtbo files).
Typically, this is the type of file the firmware loads at boot as a basis to create the final Devicetree (/boot/firmware/bcm2712-rpi-cm5-cm5io.dtb in our case).
This is because in the Raspberry Pi's case (like in a lot of other embedded devices) it's the bootloader's job to provide Linux with a Devicetree (see the Raspberry Pi docs).
A very important concept for this article are Devicetree overlays:
Overlays define further hardware, like a sensor, that isn't part of the base .dtb Devicetree.
Creating a base .dtb file for each and every possible hardware combination would be ridiculous.
Therefore, there are .dtbo files, Devicetree overlays.
These describe how the base Devicetree should be extended to support whatever hardware the overlay is for.
We'll get into the details of how overlays look like later.
For now it suffices that the Raspberry Pi already comes with a lot of overlays in /boot/firmware/overlays.
These overlays are also in the form of Devicetree blobs.
You can find their source in the Raspberry Pi's kernel git repo.
We were quite surprised at the plethora of hardware the Raspberry Pi people created overlays for.
DS18B20: Enable One-Wire
So let's tackle the first of our three sensors: the DS18B20 One-Wire temperature sensor.
The Raspberry Pi comes with an overlay for the One-Wire interface, this is it's source.
Because One-Wire comes with an enumeration protocol, we don't need to specify what sensor we use — it suffices to enable the One-Wire interface by loading the w1-gpio overlay.
You do that by editing the /boot/firmware/config.txt file and add this line under the [all] section:
dtoverlay=w1-gpio
This instructs the bootloader to integrate overlay from the /boot/firmware/overlays/w1-gpio.dtbo file into the Devicetree to hand over to Linux.
Therefore, you always need to reboot after adjusting the config.txt, it's the config for the bootloader.
You can check by reading the bootloader log with sudo vclog --msg.
If you've saved the original Devicetree, you can also use dtdiff to compare them.
Lastly, the virtual filesystem exposes the temperature reading through /sys/bus/w1/devices/28-0000112202bc/temperature (the id 0000112202bc varies with the hardware).
Btw, this change to the config.txt is exactly what rpi-config does when you enable One-Wire with it.
MCP3008: Configure SPI
Once we know the temperature we want to approach the ADC, connected through SPI0 and chip-select GPIO18.
Firstly, we enable the SPI0 interface with one chip-select pin by loading the spi0-1cs overlay.
By specifying the dtparam cs0_pin, a Devicetree parameter, we define what chip-select pin we want to use.
We simply add the following line to the config.txt:
dtoverlay=spi0-1cs,cs0_pin=18
But SPI doesn't support any enumeration.
Therefore, we need to manually describe the hardware in the Devicetree.
The Raspberry Pi already comes with an overlay for the MCP3008.
Initially, we used that by adding this line to the config.txt:
dtoverlay=mcp3008,spi0-0-present=on
Unfortunately, the Raspberry Pi's overlay for the MCP3008 doesn't expose the vref-supply attribute.
Therefore, we need to create a custom Devicetree overlay:
/dts-v1/;
/plugin/;

/ {
  compatible = "brcm,bcm2712";

  fragment@0 {
    target-path = "spi0/spidev@0";
    __overlay__ {
      status = "disabled";
    };
  };

  fragment@1 {
    target-path = "spi0";
    __overlay__ {
      status = "okay";
      #address-cells = <1>;
      #size-cells = <0>;

      adc@0 {
        compatible = "microchip,mcp3008";
        reg = <0>;
        vref-supply = <&vdd_3v3_reg>;
        spi-max-frequency = <1000000>;
      };
    };
  };
};
This overlay, which applies to the brcm,bcm2712 compatible (the Raspberry Pi 5's main processor), does two things:
fragment@0disables the existing, genericspidev@0placeholder child on thespi0interface.fragment@1addresses thespi0node and gives it a new child node,adc@0. This child has themicrochip,mcp3208compatible attribute, uses the first chip-select pin belonging to thespi0node (GPIO18as defined by the dtparam in theconfig.txt) and properly defines thevref-supplyattribute. Btw,spi0is an alias tospi@50000(see chapter 3.3 in the Devicetree specification for more details on aliases).
Be aware that there is another shorthand syntax for overlays, which we don't use.
This other syntax is explained quite well in the Android docs.
We store this, the overlay's source, in ~/mcp3008_with_vref.dts and compile it into the right format with sudo dtc -@ -I dts -O dtb -o /boot/firmware/overlays/mcp3008_with_vref.dtbo mcp3008_with_vref.dts.
Afterwards, we change the config.txt to:
dtoverlay=spi0-1cs,cs0_pin=18
dtoverlay=mcp3008_with_vref
This loads the overlay, which we can verify with sudo vclog --msg:
005454.508: Loaded overlay 'spi0-1cs'
005456.720: dtparam: cs0_pin=18
005499.339: Loaded overlay 'mcp3008_with_vref'
If there were any problems, the kernel log would tell us (check with dmesg).
Now the /sys/bus/iio/devices/iio:device0/in_voltage_scale file reads the voltage reference and we can check the voltage readings with cat /sys/bus/iio/devices/iio\:device0/in_voltage{0..7}_raw.
There's no need for any userspace libraries (like the Python gpiozero library); the kernel does it all once properly configured like this.
What an amazing piece of software, the Linux kernel.
AIS2IH: The Annoying One
Let's go on a quick rant about Linux drivers:
- There are the absolutely awful ones: closed-source drivers. Sometimes vendors only hand you a compiled Linux module implementing a driver for some hardware. This module only works for one specific Linux version. Therefore, you can't update to any other Linux version and are stuck. Furthermore, you're just supposed to trust this opaque blob and load it into kernelspace! How awful!
- Then there are the amazing ones: upstreamed Open-Source drivers, like the one for the MCP3008.
Linux is a monolithic kernel; it isn't a microkernel like Windows.
This means that all the drivers are already part of the kernel.
Read through the single Linux kernel git repo and there they are, all the drivers.
For example,
drivers/iio/adc/mcp320x.cis the driver for the MCP3008.
When a driver is upstreamed into this git repo the users are in the best possible situation to be in. The user only has to adjust the Devicetree (if the interface doesn't support enumeration) as we did above and the kernel takes care of the hardware. Therefore, we always look for hardware with drivers upstreamed to the Linux kernel. - And then there are the somewhat dumb ones: not-upstreamed (so-called out-of-tree) Open-Source drivers. In this case there are Open-Source drivers but the vendor (for whatever stupid reason) chose not to upstream them to the Linux kernel. Therefore, you need to patch the kernel sources and build kernel modules for the specific kernel you want to use. At least you can read the source code and form trust over it. Also, you are a lot more free in your choice of kernel version. Nevertheless, it's so frustrating that these vendors didn't take the last step of properly upstreaming the drivers. This would have done the user's job so much easier (that's the dude having purchased the vendor's product).

In our case, in the AIS2IH case, the vendor, ST, chose not to upstream their Open-Source drivers.
Their instructions are, I kid you not, to add their repo as a git remote and manually merge their version into your kernel version...
And there are conflicts, because of course there are (only in README.md, but still).
These are the steps we had to perform to merge and configure the kernel sources:
sudo apt update && sudo dpkg --add-architecture arm64 && sudo apt install -y git bc bison flex libssl-dev make libssl-dev:arm64git clone https://github.com/raspberrypi/linux && cd linux && git checkout 5d39807272da852e10f3fc4467c33b57f59ecc61oldstable_20260611somehow doesn't compilegit checkout -b custom_kernelgit remote add stmems_iio_github https://github.com/STMicroelectronics/st-mems-android-linux-drivers-iio.gitgit fetch stmems_iio_githubgit checkout 0455f406e00484260474473e8fed29bddd15bfa2git checkout -b stemems_iio_branchgit checkout custom_kernelgit merge --allow-unrelated-histories custom_kernel stemems_iio_branchYes, do fix the merge conflict inREADME.mdmanually.git am stm_iio_patches/6.12.y/*-stm-*.patchKERNEL=kernel_2712make ARCH=arm64 CROSS_COMPILE=aarch64-linux-gnu- bcm2712_defconfigmake ARCH=arm64 CROSS_COMPILE=aarch64-linux-gnu- menuconfigand
- mark as module: Device Drivers/Industrial I/O support/STM MEMS Device drivers
- mark as module: Device Drivers/Industrial I/O support/STM MEMS Device drivers/Accelerometer/STMicroelectronics LIS2DW12/IIS2DLPC/AIS2IH Accelerometer Driver
Afterwards we could compile the kernel like normal, install it onto the Raspberry Pi and boot, see my article on that.
The relevant module that all this effort adds is st_lis2dw12_spi.
Once we've configured the Devicetree, Linux loads this module automatically:
/dts-v1/;
/plugin/;

/ {
  compatible = "brcm,bcm2712";

  fragment@0 {
    target-path = "spi1/spidev@0";
    __overlay__ {
      status = "disabled";
    };
  };

  fragment@1 {
    target-path = "spi1";
    __overlay__ {
      status = "okay";
      #address-cells = <1>;
      #size-cells = <0>;

      accelerometer@0 {
        compatible = "st,ais2ih";
        reg = <0>;
        spi-max-frequency = <1000000>;
      };
    };
  };
};
Like before, we compile this Devicetree overlay with sudo dtc -@ -I dts -O dtb -o /boot/firmware/overlays/ais2ih.dtbo ais2ih.dts and configure config.txt like so:
dtoverlay=spi1-1cs,cs0_pin=16
dtoverlay=ais2ih
With that done, run cat /sys/bus/iio/devices/iio\:device1/in_accel_{x,y,z}_* to read the acceleration.
Isn't it fascinating how this one data structure, the Devicetree, can describe the entire hardware configuration? The bootloader can do all it needs to do, initialize hardware, enumerate things, load overlays; all to build a single Devicetree to hand Linux and let the kernel do its thing. The Devicetree is quite the clean interface and now we know how to bend it to our will.
Similar Articles

Real-Time Linux on RISC-V
27th June, 2025 8min
Setting up Linux v6.12 on a StarFive VisionFive 2 with PREEMPT_RT. Also: How to setup your Linux laptop as a simple NAT router.

Dabbling with Zephyr Driver Development: STM32 direct LCD Driver
31st May, 2026 5min
I want to use an LCD glass on an STM32WB55RG, which has an LCD direct driver in hardware. You directly connect all LCD segment and common pins to the SoC. Because I want to use Zephyr but Zephyr doesn't have an LCD driver already, I implemented one myself.

Automatic Firmware Generation for Spaceflight Hardware based on Schematics
19th August, 2026 15min
The interaction between hardware design and firmware implementation requires strict consistency in embedded systems. Firmware must exactly match the schematic-level component configuration and connectivity. In current workflows, this consistency is largely ensured through manual inspection and extensive testing. In this work, we introduce a schematics-aware approach to automate firmware generation. We propose the Group Netlist, a design- and PCB tool-agnostic abstraction of hardware. Using a reference implementation, we demonstrate our proposal for the open-source PCB design suite KiCad. As added benefit our approach serves for hardware verification purposes that we demonstrate through a fault-injection analysis. Considering relevant cases, our tool detects 75% of otherwise undetected injected faults and requires negligible overhead (less than 0.2% codebase addition and on average a 4.8% runtime increase). Lastly, we verify our tooling by successfully using it in the development workflow of an embedded satellite module.

Mistakes in the Docs: UART on Raspberry Pi 5 Compute Module
8th June, 2026 4min
We have a Raspberry Pi Compute Module 5 IO Board without a monitor or network connection. How do you see what the system is doing? How to read the Linux and bootloader log? A simple answer is UART. Turns out, UART isn't so simple on the Raspberry Pi 5 and its documentation, datasheet and raspi-config is wrong in a couple of places.